Kids OK with adultESP32Level 3/3
4-Legged Crawler Robot (12 servos)
A low, spider-style walking robot: 12 servos, three per leg, and it can wave hello.
Sign in to save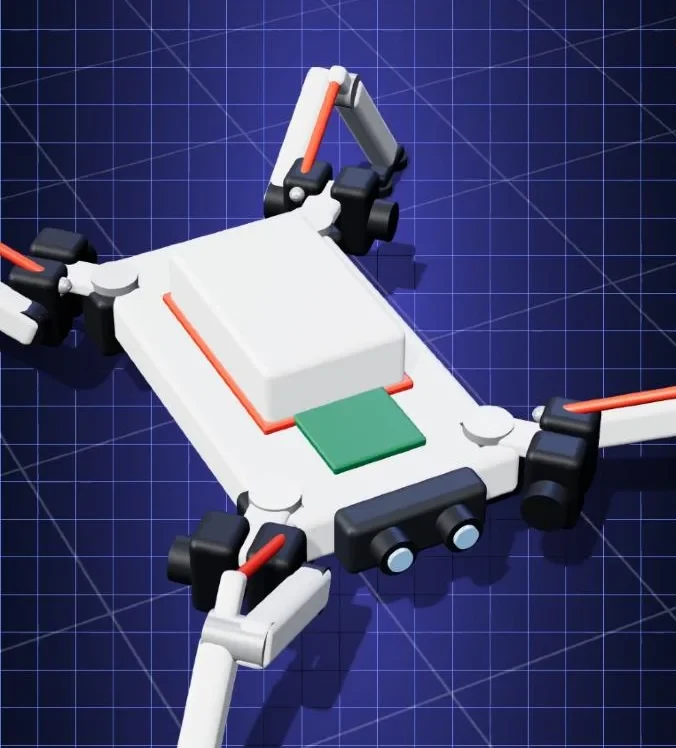
Kids OK, with an adult
DIY project. Children must build this only with an adult (16+ years) beside them at all times. Not suitable for children under 8 years.
The battery pack must be handled and charged by the adult. Power the servos from the converter, never from the ESP32.
Strictly follow the description given with this video.
Video
The video link will be added here soon.
How it works
- Each leg has three servos: the hip swings it forward and back, the thigh lifts it, and the knee bends through a push rod.
- The servos sit up in the body, so the legs stay light.
- It walks one leg at a time (front-left, rear-right, front-right, rear-left), so three feet always stay on the ground.
- An ESP32 sends the angles to a 16-channel servo driver; a battery pack feeds the servo bus through a converter.
Parts you need
Wiring
PowerGroundSignal
| # | From | Connect to |
|---|---|---|
| 1 Signal | Servo driver SDA | ESP32 D21 |
| 2 Signal | Servo driver SCL | ESP32 D22 |
| 3 Power | Servo driver VCC | ESP32 3V3 |
| 4 Ground | Servo driver GND | ESP32 GND |
| 5 Power | Battery + | Converter IN+ |
| 6 Ground | Battery − | Converter IN− |
| 7 Power | Converter OUT 6V | Servo driver V+ and ESP32 VIN |
| 8 Ground | Converter OUT − | Common GND |
| 9 Signal | Front-left hip / thigh / knee servos | Channels 0 / 1 / 2 |
| 10 Signal | Front-right hip / thigh / knee servos | Channels 3 / 4 / 5 |
| 11 Signal | Rear-left hip / thigh / knee servos | Channels 6 / 7 / 8 |
| 12 Signal | Rear-right hip / thigh / knee servos | Channels 9 / 10 / 11 |
3D print files
This project has no 3D-printed parts.